
Fourier describes GR-3 as approximately 71 kg and lists up to 55 actuators with optional 12-degree-of-freedom dexterous hands.
Source 1○ Not tested by ROBODROMO yetHumanoids
Fourier GR-3
A humanoid for social interaction in public spaces. It suits managed installations; expressive hardware and remote-control options are not proof of care benefits or household usefulness.
Payload and movementApproximately 3 kg per arm and 6.1 km/h walking speed are maker specifications.Manufacturer source
ControllerUbuntu 22.04; AMD Ryzen 7 8845HS, 32 GB memory and 1 TB storage.Manufacturer source
ConnectionsUSB Type-C, USB 3.0, Ethernet and Wi-Fi 6.Manufacturer source
Environment0–45°C and 20–80% relative humidity, non-condensing.Manufacturer source
Recorded specifications, with their source limits. These are not our measurements. See all specifications and configurations
Price and availability
No current delivered price or availability has been confirmed here. Ask for a dated quote for the exact package.
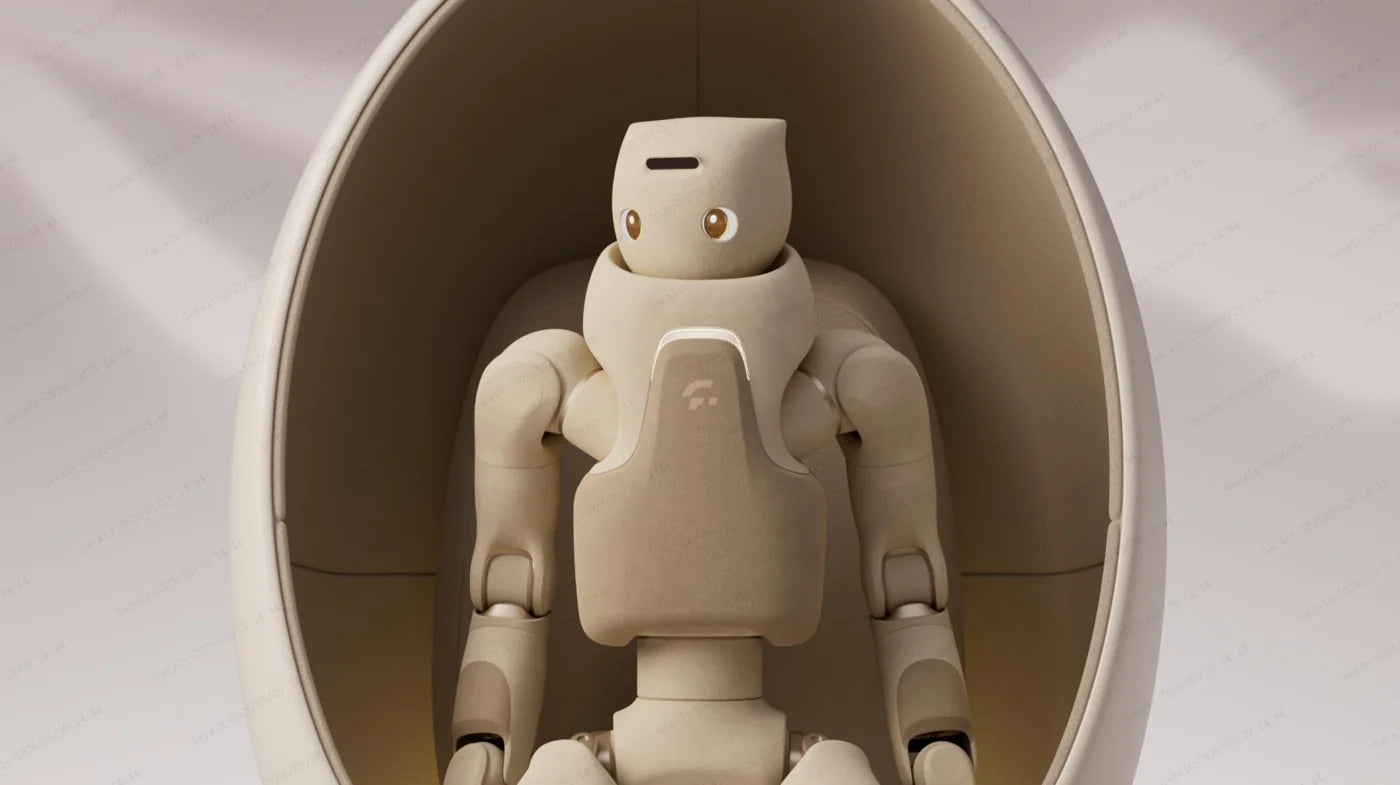
Image and credit
Manufacturer image and sourceTest track0 attempts run
We have not physically tested this robot. The task plan below is a starting point, subject to the exact unit and supported functions.
See the proposed test trackOn the ROBODROMO
test track
Three proposed tasks. Ten attempts at each suitable task, with the outcome, time and human help recorded. Confirm the exact robot, software and safe setup first. These tasks are not evidence that this robot can do them.
Complete one supported service task
Proposed task. 0 of 10 attempts run.
Repeat with a second supported destination or input
Proposed task. 0 of 10 attempts run.
Restart the task and record all operator help
Proposed task. 0 of 10 attempts run.
Pick a square to see what each attempt will record.
We will record the outcome, time, control mode, human help, safety stops, exact hardware and software, conditions and full video.
Proposed attempt; not run Only proceed if the exact unit supports the task and the setup is suitable. Keep remote control, scripted operation and autonomous operation separate. A completed attempt alone does not prove autonomy.What each square will show
Finished without extra helpNeeded a person’s helpFailedNot run yet
Keep the conditions visible
Name the control mode, surface, object or prompt and every intervention. Ten attempts are an initial result, not proof of long-term reliability.
Read our proposed test methodHow much do we really
know?
Separate our own tests from published claims and the limits of the evidence. The counts below describe records, not performance or confidence scores.
Tested by ROBODROMO
We have not physically tested this robot. No performance score or measured attempt is available.
See the proposed test track01 / The assessment
What the evidence supports.
Capability and readiness are separate. These written findings are not a numerical rating or a physical test.
Capability
What can it actually do?
The specific maker claims and any independent observations are listed below. We have not run our own task tests on this robot.
Read the source-based assessmentReadiness
Could you use it in real life?
Intended use: Social interaction in public settings. Dependable everyday use has not been established by the evidence reviewed. Optional hand actuator counts are not universal. Remote operation cannot establish independent care outcomes.
Read the source-based assessmentA clear limit
This is a research profile based on the sources below, not a hands-on test. Maker claims remain attributed to the maker; they do not prove repeatable performance in your home or workplace.
02 / Can it actually do it?
The claims, with their context.
The wording below keeps each source’s limits. A demonstration, a maker’s claim and a repeatable real-world result are different things.
Its GR-3 overview lists approximately 3 kg single-arm payload, approximately three-hour runtime and VR headset or exoskeleton teleoperation. Actual workload and supplied equipment are not established.
Source 1Fourier lists hearing, vision and touch interaction hardware including a monocular camera, microphone, speaker and tactile sensors on head and torso.
Source 1Fourier’s GR-3 teleoperation guide warns of possible power cut-off when charging completes or the battery reaches its last bar. Its forced-shutdown sequence calls for fall protection and then hoisting the robot. This is setup-specific manufacturer guidance, not an independent safety assessment.
Source 2Check the original sources
Every source keeps its original check date. Manufacturer information, research configurations and independent observations have different limits.
Open the source listKnow the exact robot
The name alone may not tell you which hardware, software or support you get. Keep editions and optional equipment separate.
Specifications and configuration
Technical reference
Specifications and configuration
The figures and features below come from the named sources. They are not independent measurements. Optional hardware and conflicting revisions are kept separate.
| Item | Documented detail | Evidence |
|---|---|---|
| Mass and joint configuration | Fourier describes GR-3 as approximately 71 kg and lists up to 55 actuators with optional 12-degree-of-freedom dexterous hands. | Source 1 |
| Load, runtime and control | Its GR-3 overview lists approximately 3 kg single-arm payload, approximately three-hour runtime and VR headset or exoskeleton teleoperation. Actual workload and supplied equipment are not established. | Source 1 |
| Sensors | Fourier lists hearing, vision and touch interaction hardware including a monocular camera, microphone, speaker and tactile sensors on head and torso. | Source 1 |
| Dimensions | 1,642 × 552 × 292 mm. Listed arm span: 1,395 mm, up to 1,759 mm with the specified 12-DoF hands. |
Maker source 31 Oct 2026 |
| Body joints | Head 2; each arm 7; waist 3; each leg 6. Optional hand configuration changes the total actuator count. |
Maker source 31 Oct 2026 |
| Battery capacity | 702 Wh plus 234 Wh; nominal 46.8 V. Battery masses listed as 3.8 kg plus 1.3 kg. |
Maker source 31 Oct 2026 |
| Charging | Approximately 1.5 hours; hot-swappable battery replacement is listed. Confirm the approved replacement procedure. |
Maker source 31 Oct 2026 |
| Main computer | AMD Ryzen 7 8845HS; Ubuntu 22.04. The processor table lists 32 GB memory and 1 TB storage. |
Maker source 31 Oct 2026 |
| Interfaces | Type-C, USB 3.0 and RJ45; Ethernet and Wi-Fi 6. |
Maker source 31 Oct 2026 |
| Environment | 0–45°C and 20–80% relative humidity, non-condensing. |
Maker source 31 Oct 2026 |
An omitted measurement is unknown in this review, not zero or unsupported. Check the exact hardware edition and documentation before ordering or designing around it.
GR-3 technical table: 1,642 × 552 × 292 mm and approximately 71 kg; the introductory height is rounded to 165 cm.
Manufacturer sourceUp to 55 actuators with optional 12-DoF hands; base hands have six DoF each. Seven DoF per arm, three at the waist and six per leg.
Manufacturer sourceApproximately 3 kg per arm and 6.1 km/h walking speed are maker specifications.
Manufacturer source702 Wh + 234 Wh battery arrangement; approximately three hours runtime and 1.5 hours charging. Hot swapping is supported.
Manufacturer sourceUbuntu 22.04; AMD Ryzen 7 8845HS, 32 GB memory and 1 TB storage.
Manufacturer sourceUSB Type-C, USB 3.0, Ethernet and Wi-Fi 6.
Manufacturer source0–45°C and 20–80% relative humidity, non-condensing.
Manufacturer sourceThe exact model and configuration
The exact model
Meet Fourier GR-3
Keep GR-3 separate from GR-1, GR-2 and Fourier’s wheeled GR-W. Fourier’s figures include an optional 12-degree-of-freedom hand configuration; record the actual hands, software and supply configuration before comparing specifications.
Further assessment notes
Setup, support and daily use
04 / Living with it
Right robot, right expectations.
What ownership could involve
A prospective buyer should obtain the exact hand and software configuration, documentation and a written regional support and parts offer. Determine whether demonstrations are remotely controlled and whether an intended interaction can run without an operator. A 71 kg walking machine needs a site-specific plan for falls, clearance, supervision, emergency stops and safe handling. The reported battery runtime and payload are not tested here, and a payload figure alone does not establish a usable grasp. For interaction with vulnerable people, agree consent, escalation, privacy and the limits of any conversational software. No checked purchase price or independent care outcome is available.
Support, software and repairs
Fourier provides joint limits, interface diagrams and teleoperation/development documentation. Its manual describes a 90–260 V AC adapter and 54.6 V/12 A maximum output. Confirm the exact hand, battery and control package, safe hot-swap procedure, firmware compatibility, warranty and regional repair support before use.
Questions still open
What needs checking before you decide.
- The optional-hand actuator count is not a universal configuration.
- Teleoperation support is not proof of autonomous task competence.
- No task footage or independent repeated-use evidence assessed.
See it in action
Our filmed attempts will appear after testing. Existing footage below keeps its original description and limitations.
See the robot
Fourier GR-3: How to Be a Good Robot?
Play video
Published by Fourier. This presentation shows the named robot. Demonstrated functions and accessories may depend on the configuration and software version.
Before you buy
Get these answered in writing by the seller. Tick them off as you go.
0 of 6 answered
Your checklist records your progress. A tick is not verification by ROBODROMO.
Sources and checks
A check date tells you when a source was read. It does not mean every claim, price or offer is unchanged today.
Sources and checks
03 / Recorded evidence
The latest checks on file.
Dates below describe the recorded checks. They do not mean the manufacturer’s page was checked today.
- support.fftai.com Source checked 2026-10-27
-
support.fftai.com
Teleoperation guide sections 5.1–5.2
Source checked 2026-10-29 -
Manufacturer specifications and support
Official product-page specification and support text; source checked dcff9480ed911b8089
Source checked 2026-10-31 -
Video and publisher attribution
YouTube title and publisher checked against the named model. Not watched in full; not an independent performance assessment.
Source checked 2026-10-31
No recorded sources in this filter.
How sure are we?
4 linked sources. Read the claims and their limits below. A source count is not a confidence score.
Keep this robot on your radar.
Register your interest in this model and receive ROBODROMO’s robot updates.
We’ll record your interest. Personalised weekly alerts are not yet available. Privacy policy