
Hiwonder lists 12 degrees of freedom, approximately 1.65 kg, a Jetson Nano controller and an 11.1 V 3500 mAh battery.
Source 1○ Not tested by ROBODROMO yetRobot dogs
Hiwonder ROSPug
A four-legged robot for learners willing to configure robotics software. It suits coding experiments, but software versions and upgrade limits matter when choosing a project.
PlatformJetson Nano with high-voltage bus servos, LiDAR and camera.Manufacturer source
Software baselineUbuntu 18.04 and ROS Melodic in the retained guide.Manufacturer source
Power11.1 V lithium battery; supplied dedicated charger; about one-hour charging stated.Manufacturer source
ColoursBlack and gun-grey versions are described as functionally identical.Manufacturer source
Recorded specifications, with their source limits. These are not our measurements. See all specifications and configurations
Price and availability
No current delivered price or availability has been confirmed here. Ask for a dated quote for the exact package.
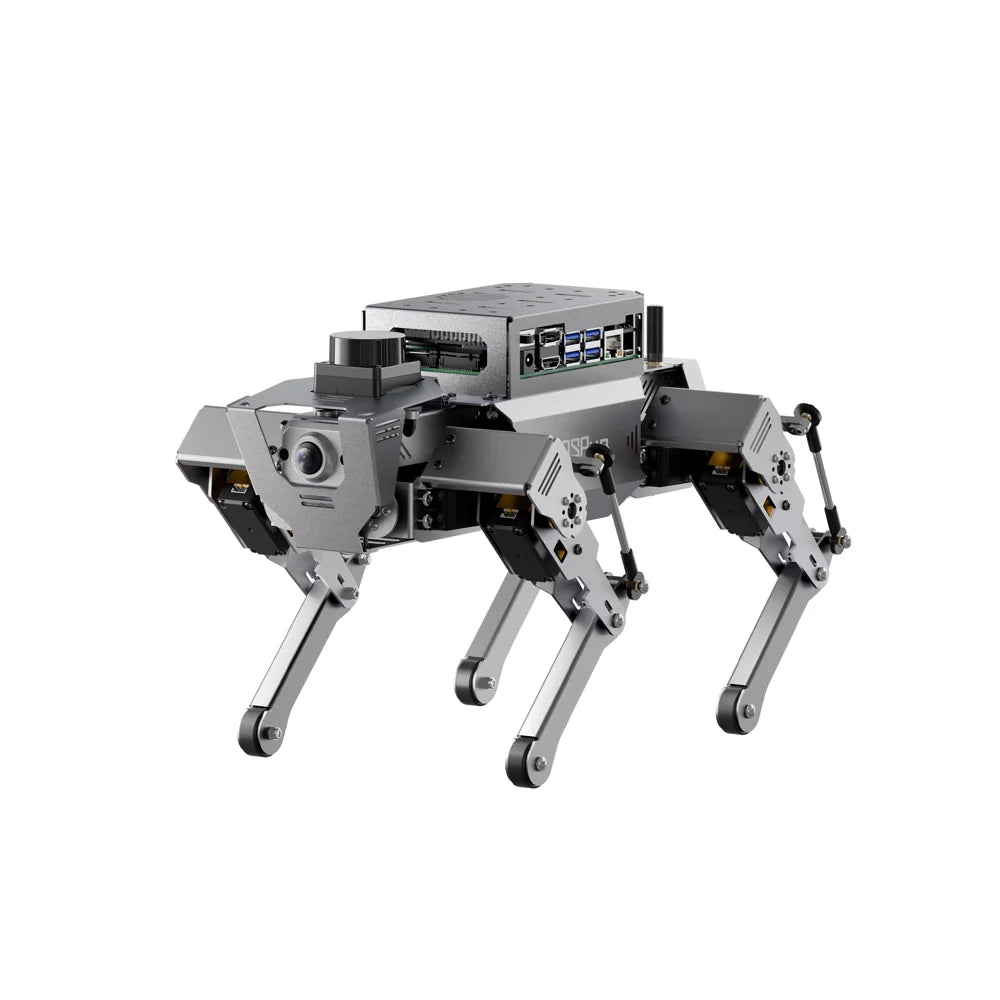
Image and credit
Manufacturer image and sourceTest track0 attempts run
We have not physically tested this robot. The task plan below is a starting point, subject to the exact unit and supported functions.
See the proposed test trackOn the ROBODROMO
test track
Three proposed tasks. Ten attempts at each suitable task, with the outcome, time and human help recorded. Confirm the exact robot, software and safe setup first. These tasks are not evidence that this robot can do them.
Follow a short route through a doorway
Proposed task. 0 of 10 attempts run.
Stop at a marked point on command
Proposed task. 0 of 10 attempts run.
Repeat the route on a second permitted surface
Proposed task. 0 of 10 attempts run.
Pick a square to see what each attempt will record.
We will record the outcome, time, control mode, human help, safety stops, exact hardware and software, conditions and full video.
Proposed attempt; not run Only proceed if the exact unit supports the task and the setup is suitable. Keep remote control, scripted operation and autonomous operation separate. A completed attempt alone does not prove autonomy.What each square will show
Finished without extra helpNeeded a person’s helpFailedNot run yet
Keep the conditions visible
Name the control mode, surface, object or prompt and every intervention. Ten attempts are an initial result, not proof of long-term reliability.
Read our proposed test methodHow much do we really
know?
Separate our own tests from published claims and the limits of the evidence. The counts below describe records, not performance or confidence scores.
Tested by ROBODROMO
We have not physically tested this robot. No performance score or measured attempt is available.
See the proposed test track01 / The assessment
What the evidence supports.
Capability and readiness are separate. These written findings are not a numerical rating or a physical test.
Capability
What can it actually do?
The specific maker claims and any independent observations are listed below. We have not run our own task tests on this robot.
Read the source-based assessmentReadiness
Could you use it in real life?
Intended use: ROS quadruped learning. Dependable everyday use has not been established by the evidence reviewed. Software generation and upgrade limits affect usable learning projects. A dated upgrade reply is not a future-support promise.
Read the source-based assessmentA clear limit
This is a research profile based on the sources below, not a hands-on test. Maker claims remain attributed to the maker; they do not prove repeatable performance in your home or workplace.
02 / Can it actually do it?
The claims, with their context.
The wording below keeps each source’s limits. A demonstration, a maker’s claim and a repeatable real-world result are different things.
The manual describes ROS Melodic and Ubuntu 18.04, with lessons covering motion, vision, lidar and navigation. Course availability is not evidence of successful task execution.
Source 2A maker reply dated 25 August 2024 says the ROS 1 model cannot be directly upgraded to ROS 2. An earlier reply rejects Jetson Orin Nano compatibility. These dated statements require checking against the exact current offer.
Source 3Check the original sources
Every source keeps its original check date. Manufacturer information, research configurations and independent observations have different limits.
Open the source listKnow the exact robot
The name alone may not tell you which hardware, software or support you get. Keep editions and optional equipment separate.
Specifications and configuration
Technical reference
Specifications and configuration
The figures and features below come from the named sources. They are not independent measurements. Optional hardware and conflicting revisions are kept separate.
| Item | Documented detail | Evidence |
|---|---|---|
| Joints, controller and power | Hiwonder lists 12 degrees of freedom, approximately 1.65 kg, a Jetson Nano controller and an 11.1 V 3500 mAh battery. | Source 1 |
| Operating system | The manual describes ROS Melodic and Ubuntu 18.04, with lessons covering motion, vision, lidar and navigation. Course availability is not evidence of successful task execution. | Source 2 |
| Upgrade limits | A maker reply dated 25 August 2024 says the ROS 1 model cannot be directly upgraded to ROS 2. An earlier reply rejects Jetson Orin Nano compatibility. These dated statements require checking against the exact current offer. | Source 3 |
An omitted measurement is unknown in this review, not zero or unsupported. Check the exact hardware edition and documentation before ordering or designing around it.
Jetson Nano with high-voltage bus servos, LiDAR and camera.
Manufacturer sourceUbuntu 18.04 and ROS Melodic in the retained guide.
Manufacturer source11.1 V lithium battery; supplied dedicated charger; about one-hour charging stated.
Manufacturer sourceBlack and gun-grey versions are described as functionally identical.
Manufacturer sourceThe exact model and configuration
The exact model
Meet Hiwonder ROSPug
The retained getting-started guide describes Jetson Nano with Ubuntu 18.04 and ROS Melodic. It says black and gun-grey models differ only in appearance. Do not substitute Jetson Orin Nano or assume a ROS 2 edition.
Further assessment notes
Setup, support and daily use
04 / Living with it
Right robot, right expectations.
What ownership could involve
Obtain the installed software image, recovery procedure and update commitments before choosing it for a course. Confirm whether required packages remain obtainable and who supports the complete stack. A tutorial index is useful, but it is not proof that a fresh installation works. Keep a known-good backup before experimenting. The manual warns about fingers near joints, falls from edges and servo heating; these are practical reasons for a controlled test area and supervised use. It also treats servos as consumables. Ask for replacement availability, battery and charger details, warranty handling and landed cost. Current support life and UK service arrangements are unverified. Avoid buying on an assumed future ROS 2 upgrade.
Support, software and repairs
The software baseline is old; confirm maintained images and security/update arrangements rather than assuming a current Ubuntu/ROS release. Hiwonder provides wiring and battery instructions. Verify current spare servos, battery availability, warranty and the supplied SDK before purchase; educational code is not a promise of production reliability.
Questions still open
What needs checking before you decide.
- The dated upgrade reply is not a promise about later hardware.
- No independent navigation reliability, runtime or sustained classroom assessment.
- Current software maintenance, source-code licensing and regional support remain unresolved.
See it in action
Our filmed attempts will appear after testing. Existing footage below keeps its original description and limitations.
See the robot
ROSPug Quadruped Bionic Robot Dog Powered by Jetson Nano ROS Open Source Python Programming
Play video
Published by Hiwonder. ROSPug presentation using Jetson Nano. Check current hardware and software configuration with the supplier.
Before you buy
Get these answered in writing by the seller. Tick them off as you go.
0 of 6 answered
Your checklist records your progress. A tick is not verification by ROBODROMO.
Sources and checks
A check date tells you when a source was read. It does not mean every claim, price or offer is unchanged today.
Sources and checks
03 / Recorded evidence
The latest checks on file.
Dates below describe the recorded checks. They do not mean the manufacturer’s page was checked today.
- hiwonder.com Source checked 2026-10-27
- wiki.hiwonder.com Source checked 2026-10-27
- hiwonder.com Source checked 2026-10-27
-
Manufacturer specifications and support
Exact-model specification/support passages in official source; numerical claims are manufacturer figures.
Source checked 2026-10-31 -
Video and publisher attribution
YouTube title and publisher checked against the named model. ROSPug presentation using Jetson Nano. Check current hardware and software configuration with the supplier. Not watched in full; not an independent performance assessment.
Source checked 2026-10-31
No recorded sources in this filter.
How sure are we?
5 linked sources. Read the claims and their limits below. A source count is not a confidence score.
Keep this robot on your radar.
Register your interest in this model and receive ROBODROMO’s robot updates.
We’ll record your interest. Personalised weekly alerts are not yet available. Privacy policy