
The manufacturer calls X1 a full-stack open-source robot and describes construction, hardware and software materials with links. Downloads, licence permissions and delivered support were not independently verified.
Source 2○ Not tested by ROBODROMO yetHumanoids
AGIBOT X1
A humanoid with published build materials for developers. It suits engineering projects, but useful tasks and ongoing support need more work than simply assembling the hardware.
Size and motion130 cm; 33 kg; 34 active degrees of freedom and 1 m/s maximum walking speed, per product page.Source 1
Power and loadMaker lists 2-hour runtime and 0.5 kg single-arm load; operating conditions are not stated.Source 1
Build materialsGuide describes 29 joints, two grippers and optional head expansion; design files and code links are provided.Source 2
Body130 cm; 33 kg; 34 active degrees of freedom.Manufacturer source
Recorded specifications, with their source limits. These are not our measurements. See all specifications and configurations
Price and availability
No current delivered price or availability has been confirmed here. Ask for a dated quote for the exact package.
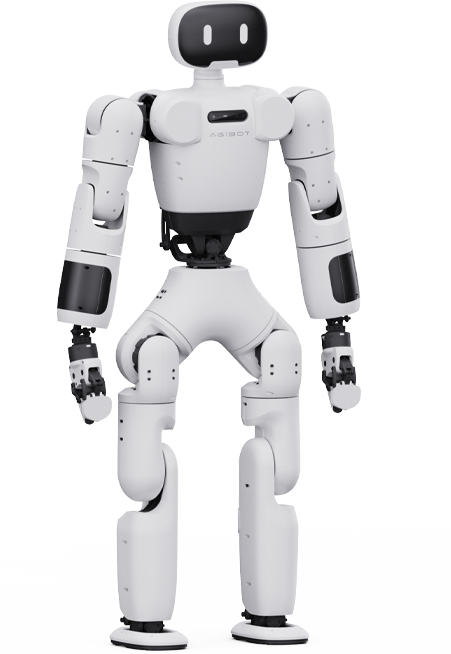
Image and credit
Image retained from this robot’s existing profile.Test track0 attempts run
We have not physically tested this robot. The task plan below is a starting point, subject to the exact unit and supported functions.
See the proposed test trackOn the ROBODROMO
test track
Three proposed tasks. Ten attempts at each suitable task, with the outcome, time and human help recorded. Confirm the exact robot, software and safe setup first. These tasks are not evidence that this robot can do them.
Complete one documented movement or manipulation task
Proposed task. 0 of 10 attempts run.
Repeat the task from the same starting setup
Proposed task. 0 of 10 attempts run.
Record all help needed to start and finish
Proposed task. 0 of 10 attempts run.
Pick a square to see what each attempt will record.
We will record the outcome, time, control mode, human help, safety stops, exact hardware and software, conditions and full video.
Proposed attempt; not run Only proceed if the exact unit supports the task and the setup is suitable. Keep remote control, scripted operation and autonomous operation separate. A completed attempt alone does not prove autonomy.What each square will show
Finished without extra helpNeeded a person’s helpFailedNot run yet
Keep the conditions visible
Name the control mode, surface, object or prompt and every intervention. Ten attempts are an initial result, not proof of long-term reliability.
Read our proposed test methodHow much do we really
know?
Separate our own tests from published claims and the limits of the evidence. The counts below describe records, not performance or confidence scores.
Tested by ROBODROMO
We have not physically tested this robot. No performance score or measured attempt is available.
See the proposed test track01 / The assessment
What the evidence supports.
Capability and readiness are separate. These written findings are not a numerical rating or a physical test.
Capability
What can it actually do?
The specific maker claims and any independent observations are listed below. We have not run our own task tests on this robot.
Read the source-based assessmentReadiness
Could you use it in real life?
Intended use: Building and programming a humanoid. Dependable everyday use has not been established by the evidence reviewed. Published construction files are useful inputs; licences, functioning downloads and support still need verification.
Read the source-based assessmentA clear limit
This is a research profile based on the sources below, not a hands-on test. Maker claims remain attributed to the maker; they do not prove repeatable performance in your home or workplace.
02 / Can it actually do it?
The claims, with their context.
The wording below keeps each source’s limits. A demonstration, a maker’s claim and a repeatable real-world result are different things.
The X1 development guide links a bill of materials, design and assembly files and separate hardware, inference and training repositories. A resource link does not establish what a purchased unit includes, whether downloads work, or the licences and support for each component.
Source 3Check the original sources
Every source keeps its original check date. Manufacturer information, research configurations and independent observations have different limits.
Open the source listKnow the exact robot
The name alone may not tell you which hardware, software or support you get. Keep editions and optional equipment separate.
Specifications and configuration
Model detail
Specifications and configuration
Figures below retain their source and configuration limits. Manufacturer specifications are not independent performance results.
130 cm; 33 kg; 34 active degrees of freedom and 1 m/s maximum walking speed, per product page.
Source 1Maker lists 2-hour runtime and 0.5 kg single-arm load; operating conditions are not stated.
Source 1Guide describes 29 joints, two grippers and optional head expansion; design files and code links are provided.
Source 2130 cm; 33 kg; 34 active degrees of freedom.
Manufacturer sourceMaximum 1 m/s; two-hour stated runtime.
Manufacturer source0.5 kg per arm.
Manufacturer sourceFull-stack open-source positioning; listed domain controller offers a Linux SDK, EtherCAT/FDCAN and OTA support.
Manufacturer sourceThe exact model and configuration
The exact model
Meet AGIBOT X1
X1 is a distinct open-source platform. The product page lists 34 active degrees of freedom; the development guide describes 29 body joints, two grippers and provision for a three-degree head. Exact counting and configuration need confirmation.
Further assessment notes
Setup, support and daily use
04 / Living with it
Right robot, right expectations.
What ownership could involve
Confirm exact edition, supplied hardware and software, technical setup, operator training, site safety, connectivity, data routes, maintenance, warranty, delivery and support. No public price verified. The guide describes construction and actuator configuration, so allow for engineering setup and confirm the exact revision and support.
Support, software and repairs
AGIBOT publishes component specifications and a modular-development route. Actuator peak torque is not whole-robot payload. Confirm the shipped hand, source-code licence/version, build instructions, replacement joints and batteries. Public component descriptions do not establish repair stock or a fixed warranty/support term.
Questions still open
What needs checking before you decide.
- The guide describes 29 body joints, two grippers and optional three-axis head expansion, but does not establish how many degrees of freedom to count for each gripper. Its figures cannot safely be reconciled to the product page total without the actual configuration.
- No footage reviewed; task completion, control mode, reliability and safety are unknown.
- Listed components are not evidence of interchangeable parts or a particular serial configuration.
See it in action
Our filmed attempts will appear after testing. Existing footage below keeps its original description and limitations.
○ No test footage yet
Our filmed attempts will appear here.
No video is embedded in this profile. Check the source list for the available evidence.
Before you buy
Get these answered in writing by the seller. Tick them off as you go.
0 of 6 answered
Your checklist records your progress. A tick is not verification by ROBODROMO.
Sources and checks
A check date tells you when a source was read. It does not mean every claim, price or offer is unchanged today.
Sources and checks
03 / Recorded evidence
The latest checks on file.
Dates below describe the recorded checks. They do not mean the manufacturer’s page was checked today.
- agibot.com Source checked 2026-10-28
- agibot.com Source checked 2026-10-28
- agibot.com Source checked 2026-10-29
-
Manufacturer specifications and support
Exact-model specification/support passages in official source; numerical claims are manufacturer figures.
Source checked 2026-10-31
No recorded sources in this filter.
How sure are we?
4 linked sources. Read the claims and their limits below. A source count is not a confidence score.
Keep this robot on your radar.
Register your interest in this model and receive ROBODROMO’s robot updates.
We’ll record your interest. Personalised weekly alerts are not yet available. Privacy policy